
MRP: ₹16575
₹13577
₹ 2998 Off
(Incl. of all taxes)
Qty
Buying in bulk?
In stock
Deliver to
- 7-day returns
- Secure payment
- International shipping
- Carefully packed
Get this at ₹ 12898Extra 5% OffAdd items worth ₹999 to the cart & get extra 5% off
Get this at ₹ 12219Extra 10% OffAdd items worth ₹1499 to the cart & get extra 10% off
Book Summary
This is a new text/reference on advanced nonlinear algorithms for mechanical
systems that are based on Lypaunov-type design and stability analysis. The
presentation illustrates, in a unified framework, how recent Lyapunov-based
techniques can be used to solve a variety of nonlinear control problems for
mechanical systems.
Starting with part one, the foundations are established in a thorough manner,
including necessary math background materials. Part two covers solutions to some
tracking problems for rigid mechanical systems, i.e., systems modeled by
ordinary differential equations. Part three addresses problems of
setpoint/vibration control of flexible mechanical systems, i.e., systems modeled
by partial differential equations. By covering theory and applications, the book
addresses both
- ISBN-13
- 9780817640866
- Language
- English
- Binding
- Hard Bound
- Publisher
- Birkhäuser Boston
- Publishing Date
- 2000-06-16
- Total Pages
- 316
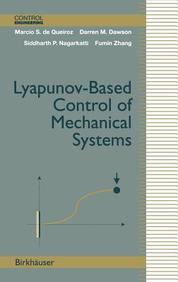
Lyapunov-Based Control Of Mechanical Systems
Frequently bought together
Total for 3 items₹13703₹16715You save ₹3012
Product Specifications
Book Summary
This is a new text/reference on advanced nonlinear algorithms for mechanical
systems that are based on Lypaunov-type design and stability analysis. The
presentation illustrates, in a unified framework, how recent Lyapunov-based
techniques can be used to solve a variety of nonlinear control problems for
mechanical systems.
Starting with part one, the foundations are established in a thorough manner,
including necessary math background materials. Part two covers solutions to some
tracking problems for rigid mechanical systems, i.e., systems modeled by
ordinary differential equations. Part three addresses problems of
setpoint/vibration control of flexible mechanical systems, i.e., systems modeled
by partial differential equations. By covering theory and applications, the book
addresses both
Book Specifications
- ISBN-13
- 9780817640866
- Language
- English
- Binding
- Hard Bound
- Publisher
- Birkhäuser Boston
- Publishing Date
- 2000-06-16
- Total Pages
- 316